Elephant Robotics myController S570Exoskeleton Controller
Original price was: $83.20.$59.36Current price is: $59.36.
47 in stock
Description
Elephant Robotics myController S570
Overview
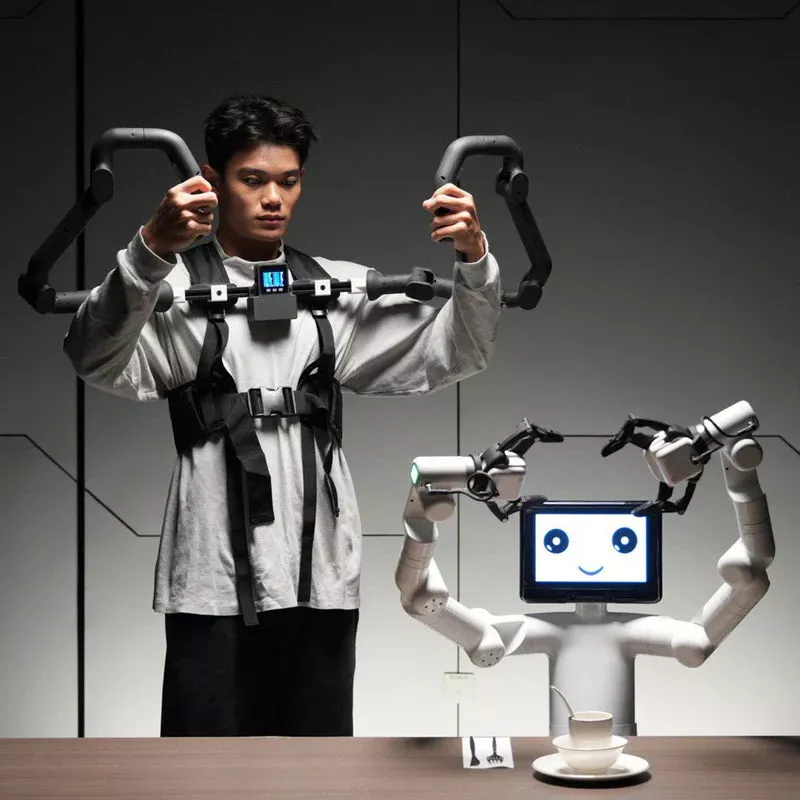
The Elephant Robotics myController S570 is a portable, wearable dual-arm exoskeleton controller for motion data collection and robot teleoperation. You wear it and move your arms, and it captures that motion to drive a connected robot in real time. It is designed to help researchers, developers, and educators apply robotics in practical and learning scenarios, particularly for end-to-end AI data collection and intuitive remote control.
It provides 12 degrees of freedom, six per arm, with a 570 mm reach per arm and a 1500 mm total span, and it weighs just 1.5 kilograms for comfortable wear. High-resolution 4096-count magnetic encoders track motion precisely, and the device samples data at up to 100 Hz, transmitting joint positions, speeds, button states, joystick states, and gyroscope data. A dual-finger grip, two joysticks, and two buttons provide control, and a 2-inch LCD shows real-time status.
The S570 connects over USB Type-C, Bluetooth, or wireless, and is broadly compatible: it works with the myCobot 280 and 320, myCobot Pro 630, myAGV, mechArm 270, myArm M750, myBuddy 280, the Mercury humanoid, and Universal Robots arms, among others. A standardized Python driver library on PyPI, together with ROS1 and ROS2 support and RViz simulation, makes teleoperation and data collection approachable even for beginners.
Specifications
| Controller | |
|---|---|
| Type | Portable wearable dual-arm exoskeleton controller for motion capture and teleoperation |
| Degrees of Freedom | 12 (6 per arm) |
| Reach | 570 mm per arm |
| Total Span | 1500 mm |
| Weight | 1.5 kg (about 750 g per arm) |
| Rotation Range | +/- 180 degrees |
| Sensing and Inputs | |
| Sensors | 4096-resolution magnetic encoders |
| Data Rate | Up to 100 Hz |
| Inputs | Dual-finger grip, 2 joysticks, and 2 buttons |
| Data Output | Joint position, speed, acceleration, button and joystick state, and gyroscope data |
| Interface and Power | |
| Display | 2-inch LCD (320 x 240, IPS) |
| Connectivity | USB Type-C, Bluetooth, and wireless |
| Power | 8.4 V, 2 A |
| Controllers | ESP32 dual-core main controller plus two ESP32 auxiliary controllers |
| Compatibility and Software | |
| Compatible Robots | myCobot 280 and 320, myCobot Pro 630, myAGV, mechArm 270, myArm M750, myBuddy 280, Mercury Humanoid, and Universal Robots arms, among others |
| Software | Python driver library (PyPI), ROS1 and ROS2, with RViz simulation and real-time robot state display |
Key Features
- Wearable Dual-Arm Exoskeleton: 12 degrees of freedom, six per arm, with 570 mm reach per arm and a 1500 mm span, at just 1.5 kg for comfortable wear.
- High-Speed, High-Resolution Capture: 4096-resolution magnetic encoders sample motion at up to 100 Hz for precise AI training and motion capture.
- Intuitive Control: A dual-finger grip, two joysticks, and two buttons let you drive a robot in a way that matches human operating habits.
- Broad Robot Compatibility: Works with myCobot, myAGV, mechArm, myArm M750, myBuddy, the Mercury humanoid, and Universal Robots arms, among others.
- Flexible Connectivity: USB Type-C, Bluetooth, and wireless, with a 2-inch LCD for real-time status.
- Open Development: A standardized Python driver library on PyPI, plus ROS1 and ROS2 support with RViz simulation.
Applications
The S570 suits research, education, and teleoperation. For AI research, it captures end-to-end motion data for training imitation-learning and other models. For teleoperation, it lets an operator control compatible robots from a distance in a natural, human-aligned way, which is valuable for measurement, rescue, and other unmanned tasks, as well as industrial workstation and humanoid-robot control.
In education, its user-friendly interface, pre-installed firmware, and documentation make it approachable for all skill levels, and it works with robots of various degrees of freedom for hands-on learning. Because it transmits standardized motion data, teams can build a teleoperation project across compatible robots without writing complex control algorithms from scratch.
Setup and Getting Started
- Unbox and inspect: Remove the myController S570 and check for shipping damage.
- Connect power: Connect the 8.4 V power adapter, and confirm the 2-inch LCD shows status.
- Connect to your computer: Connect over USB Type-C, Bluetooth, or wireless, following the documentation.
- Install the software: Install the Python driver library from PyPI, or set up the ROS1 or ROS2 environment with RViz.
- Pair with a robot: Connect a compatible robot, such as a myArm M750 or a Universal Robots arm, and confirm the S570 transmits motion data.
- Wear and operate: Put on the exoskeleton and move your arms to teleoperate the robot or record motion data.
What’s Included
- Controller: myController S570 wearable dual-arm exoskeleton (x1)
- Power Adapter: 8.4 V power adapter (x1)
- Cable: USB data cable (x1)
- Documentation: Quick-start guide and access to online documentation
Documentation and Resources
- Documentation (GitBook): docs.elephantrobotics.com
- Developer Resources: github.com/elephantrobotics
Warranty Information
The myController S570 is covered by the Elephant Robotics After-Sales Warranty Policy, covering defects in material and workmanship under normal use from the date of receipt.is an authorized Elephant Robotics dealer, so warranty support is handled through us.
| Component Category | Coverage |
|---|---|
| Mechanical Structure | 365 days (joint connectors, shells, bearings, end flange, main body) |
| Power Supply System | 365 days (DC power supplies, cables, inverters) |
| Control System | 365 days (control boards and electronics) |
Not Covered
- Damage from misuse, accident, or operation outside the documented limits
- Damage from unauthorized repair, disassembly, or modification
- Normal wear on consumable parts
Warranty service requires a valid proof of purchase or order number.
Related products
-
- Sale!
- hot sale
Jacuzzi CFR 150
- Original price was: $109.19.$83.70Current price is: $83.70.
- Add to cart
-
- Sale!
- hot sale
Jacuzzi J-200 LED Light O-Ring with 5/16 in. O.D. (2012+) (6541-688)
- Original price was: $5.60.$4.36Current price is: $4.36.
- Add to cart
-
- Sale!
- hot sale
O-Ring, Cable Connecter, Zodiac Polaris 9100, qty 2- R0545105
- Original price was: $5.32.$3.13Current price is: $3.13.
- Add to cart
-
- Sale!
- hot sale
Raypak Baffle, Kit 405 (Set Of 8) | 001302F
- Original price was: $89.91.$59.69Current price is: $59.69.
- Add to cart
-
- Sale!
- hot sale
Delta Dryden Venetian Bronze Tub and Shower System with Control Handle, 3-Setting Diverter, Showerhead, and Hand Shower with Grab Bar SS144511RB3
- Original price was: $23.95.$18.73Current price is: $18.73.
- Add to cart
-
- Sale!
- hot sale
Hayward Plate, Slide With Screw | SPX1082H1B
- Original price was: $9.15.$6.41Current price is: $6.41.
- Add to cart
-
- Sale!
- hot sale
Jacuzzi J-400 Basic Stereo, Blue Wave w/Back and Phone Holder (2013+) (6500-400)
- Original price was: $421.80.$329.56Current price is: $329.56.
- Add to cart
-
- Sale!
- hot sale
Above Ground Pool Winter Cover 16 Ft Diameter SWAG16 SWAG16-Q
- Original price was: $70.30.$44.15Current price is: $44.15.
- Add to cart